Analyze Extrinsic Parameter Error in ETH Setup
Ensure the Calibration Board Has Been Mounted
To obtain the calibration board pose and the scene point cloud containing the calibration board, check that the calibration board is mounted on the robot before evaluating ETH extrinsic parameter error. For instructions, see Calibration Board Mounting.
Build Project to Obtain Calibration Board Poses
-
Add the “Capture Images from Camera” Step.
Create a new project and add the “Capture Images from Camera” Step or the “Capture Images from Line Scan Camera” Step, or select the corresponding Step in an opened project. In the Step Parameters panel, click Select camera to select and connect the camera, then select the extrinsic parameter group to be tested.
-
Add the “Path Planning” Step.
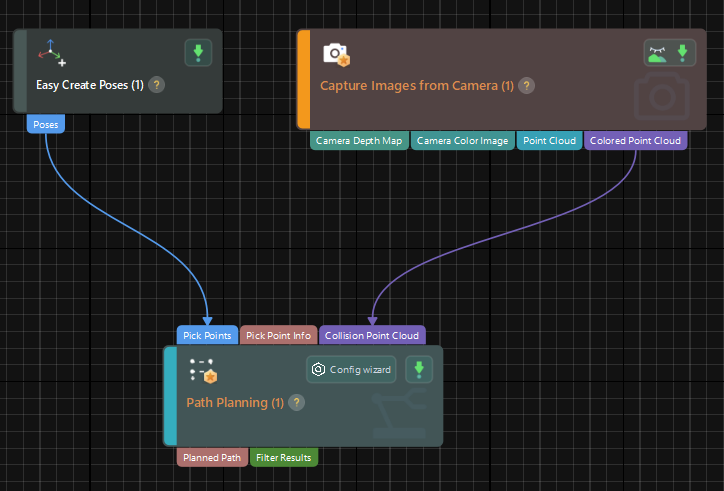
Add the “Path Planning” Step. Connect the Colored Point Cloud output port of the “Capture Images from Camera” Step or the Point Cloud output port of the “Capture Images from Line Scan Camera” Step to the Collision Point Cloud input port of the “Path Planning” Step.
-
Add the “Easy Create Poses” Step.
Add the “Easy Create Poses” Step and connect the Poses output port with the Vision Points input port of the “Path Planning” Step.
The built project is shown as below.
-
Enter the simulation interface.
In the “Path Planning” Step, click Config wizard to enter the 3D simulation area.
Synchronize the Robot Pose and Obtain a Scene Point Cloud Containing the Calibration Board
-
In the “Path Planning” Step, click Config wizard to enter the 3D simulation area.
-
Synchronize the real robot pose with the “Path Planning” tool so that the robot poses in the simulation and in reality match.
-
Click Simulate to visualize the scene point cloud containing the calibration board. You can ignore any error messages that appear after clicking Simulate.
Create Virtual TCP on the Calibration Board
-
Add an end tool to the resources in the path planning tool.
-
In the 3D simulation area, check the end tool and adjust its parameters so that the TCP coincides with the center of the circle on the calibration board. The pose axes should align with the cross at the center, and the XOY plane should coincide with the calibration board plane.
-
Enter a name and click OK to create the virtual TCP.
Check Extrinsic Parameters at Other Positions in the Workspace
-
Move the real robot to other positions in the workspace.
-
Synchronize the real robot pose with the “Path Planning” tool so that the robot poses in the simulation and in reality match.
-
Click Simulate to obtain a new point cloud of the calibration board and its surrounding scene.
-
Check whether the virtual TCP created earlier still coincides with the center of the circle on the calibration board.
Other Evaluation Suggestions
If there is a significant error in the extrinsic parameters, please refer to the following suggestions:
-
The accuracy of the extrinsic parameters is mainly influenced by the absolute accuracy of the robot. Please check the absolute accuracy of the robot.
-
Try creating different point cloud templates at different positions or teaching different pick points to compensate for the robot’s absolute accuracy.