Filter Poses by Predefined Options
This section introduces how to filter poses with the provided pose filtering options.
Five pose filtering methods are available: Filter by angle, Filter out poses out of ROI, Get highest layer poses, Filter pose by reference pose, and Extract pose in cuboid. Click the + button on the right to add them.
|
Up to three pose filtering options can be added. At most one “Filter out poses out of ROI” option or one “Get highest layer poses” option can be added. |
Filter by angle
Function
This option calculates the angle between the specified axis of the pose and the reference pose, and the poses with an angle less than the set Max angle difference will be retained.
Usage Instructions
Axis to be specified
This parameter specifies an axis of the pose, and the angle between this specified axis and the target direction will be calculated.
Set target direction
This parameter is used to set the target direction.
No. |
Method |
Description |
Instruction |
Illustration |
1 |
Robot frame |
Use the robot frame as the reference pose. |
||
2 |
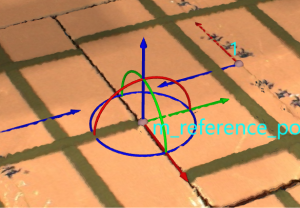
Drag with pose manipulator |
Set the reference pose with the pose manipulator. |
|
|
Filter out poses out of ROI
Get highest layer poses
Filter pose by reference pose
Function
This option compares the translational and rotational deviations between the input poses and reference poses in a common reference frame, and retains valid poses with deviations within the specified ranges. Before using this option, ensure that the input poses and reference poses are in the same reference frame.
Parameter Description
This option uses the parameters of the Filter Pose by Reference Pose Step. Refer to the Step documentation for detailed descriptions of each parameter.
Extract pose in cuboid
Function
This option retains poses within a cuboid based on the cuboid’s center pose and dimensions.
Parameter Description
This option uses the parameters of the Extract Pose in Cuboid Step. Refer to the Step documentation for detailed descriptions of each parameter.