Extract 3D Points in Cuboid

You are currently viewing the documentation for the latest version (2.2.1). To access a different version, click the "Switch version" button located in the upper-right corner of the page.

■ If you are not sure which version of the product you are currently using, please feel free to contact Mech-Mind Technical Support.

Function

Extract point clouds inside specified cuboids and discard the point clouds outside the cuboids.
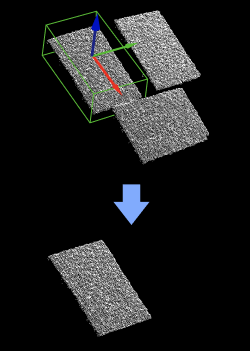
extract 3d points in cuboid functional description

Usage Scenario

A general point cloud extraction Step. No fixed usage scenarios. The dimensions of the cuboids can be input from the port or set by parameters.

Input and Output

Input

Input port Data type Description

Point Clouds

PointCloud/XYZNormal[]

Point clouds in the input list of this port will have points extracted.

Box Poses

Pose[]

List of cuboid center poses.

Half Lengths on X-Axis of Boxes

Number[]

Half of the X-length of the cuboid (optional).

Half Lengths on Y-Axis of Boxes

Number[]

Half of the Y-length of the cuboid (optional).

Half Lengths on Z-Axis of Boxes

Number[]

Half of the Z-length of the cuboid (optional).

Output

Output port Data type Description

Extracted 3D Points

PointCloud/XYZNormal[]

List of point clouds within the cuboids.

Parameter Description

Box Dimensions’ Settings

Parameter Description Illustration

Half Length of Box on X-Axis

Default value: 100.000
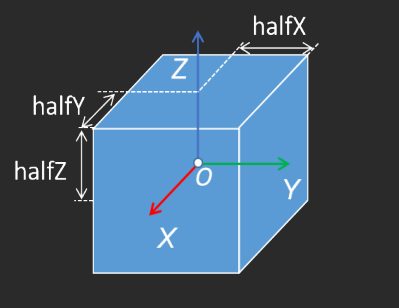
Instructions: This parameter takes the half length of the box on the X-axis in the world reference frame, corresponding to halfX in the figure below. The unit is millimeters.

extract 3d points in cuboid schematic diagram

Half Length of Box on Y-Axis

Default value: 100.000
Instructions: This parameter takes the half length of the box on the Y-axis in the world reference frame, corresponding to halfY in the figure below. The unit is millimeters.

Half Length of Box on Z-Axis

Default value: 100.000
Instructions: This parameter takes the half length of the box on the Z-axis in the world reference frame, corresponding to halfZ in the figure below. The unit is millimeters.

Usage Settings for Input Clouds

Parameter Description

Input Point Cloud Usage

Description: This parameter is used to set the correspondence between the input point cloud list and the cuboid center pose list. The Step will generate a cuboid based on the cuboid center pose and extract the points in the corresponding point cloud that are within the cuboid range.

Value list:

  • OneToOne: Each point cloud corresponds to a cuboid center pose. The cuboid generated from the first center pose is used to extract the first point cloud, the cuboid generated from the second center pose is used to extract the second point cloud, and so on.

  • FirstToAll: All cuboid center poses are used for the first point cloud. The Step will generate a cuboid based on each center pose, and extract the points within the cuboid range from the first point cloud.

  • AllToFirst: The first cuboid center pose is used for all point clouds. The Step will generate a cuboid based on the first center pose, and extract the points within the cuboid range from each point cloud.

Instructions: Please select the appropriate method according to the correspondence between the point cloud list and the cuboid center pose list.

Is this page helpful?

You can give a feedback in any of the following ways:

We Value Your Privacy

We use cookies to provide you with the best possible experience on our website. By continuing to use the site, you acknowledge that you agree to the use of cookies. If you decline, a single cookie will be used to ensure you're not tracked or remembered when you visit this website.